Selected Works
My research solves problems through creative hardware design.
I believe robots should be designed from the task first, then given mechanisms free of the constraints evolution imposed on animals.
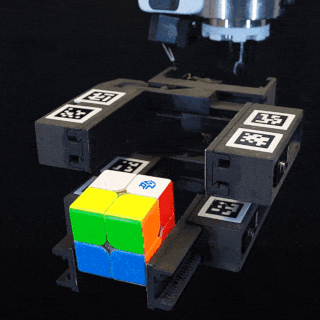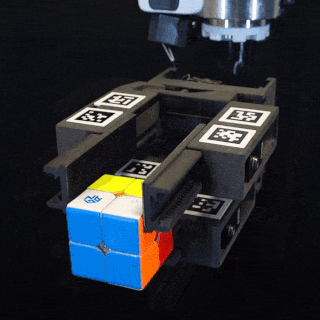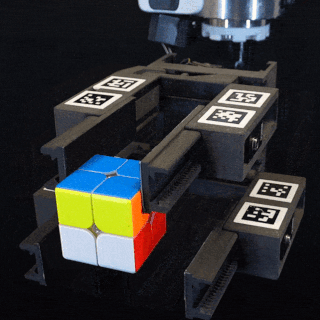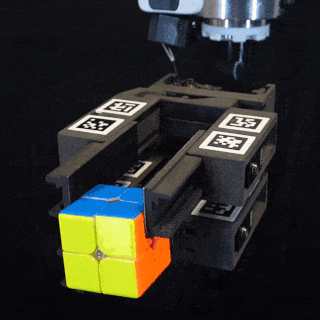
Preprint · 2026 · Co-first author
Cartesian Hand V1
Dexterous manipulation ≠ complex hand.
View project →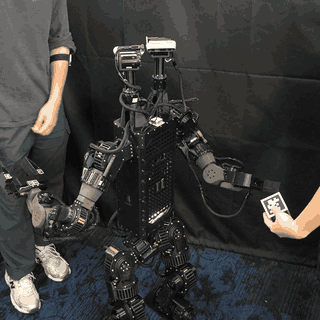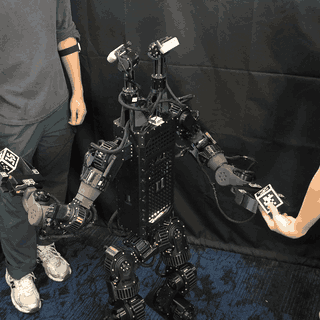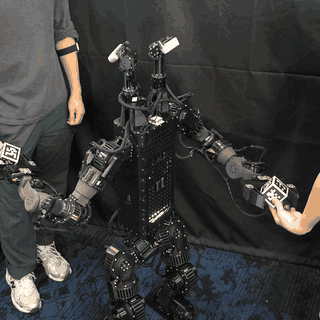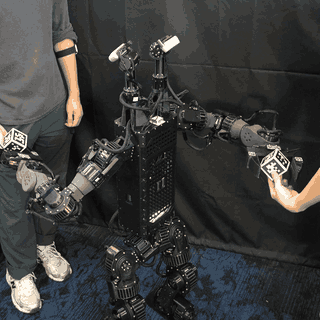
Preprint · 2026 · Mechanical design
Duke Humanoid V2
Humanoids are not humans, then how can we do better?
View project →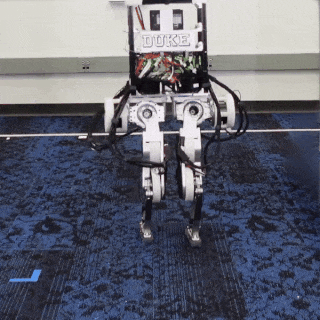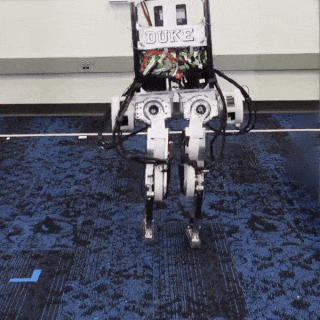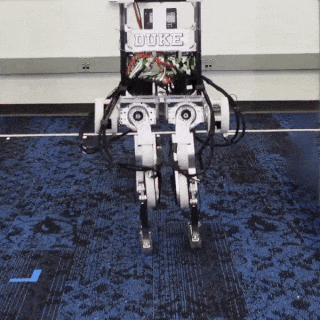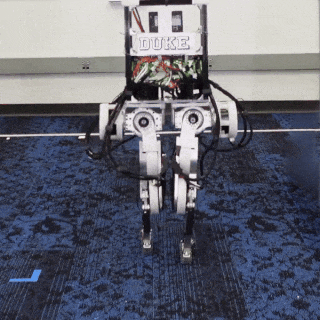
IROS 2025 · Mechanical design
Duke Humanoid V1
Exploring bipedal locomotion and what it takes to build a humanoid.
View project →