IROS 2025 · Mechanical design
Duke Humanoid V1
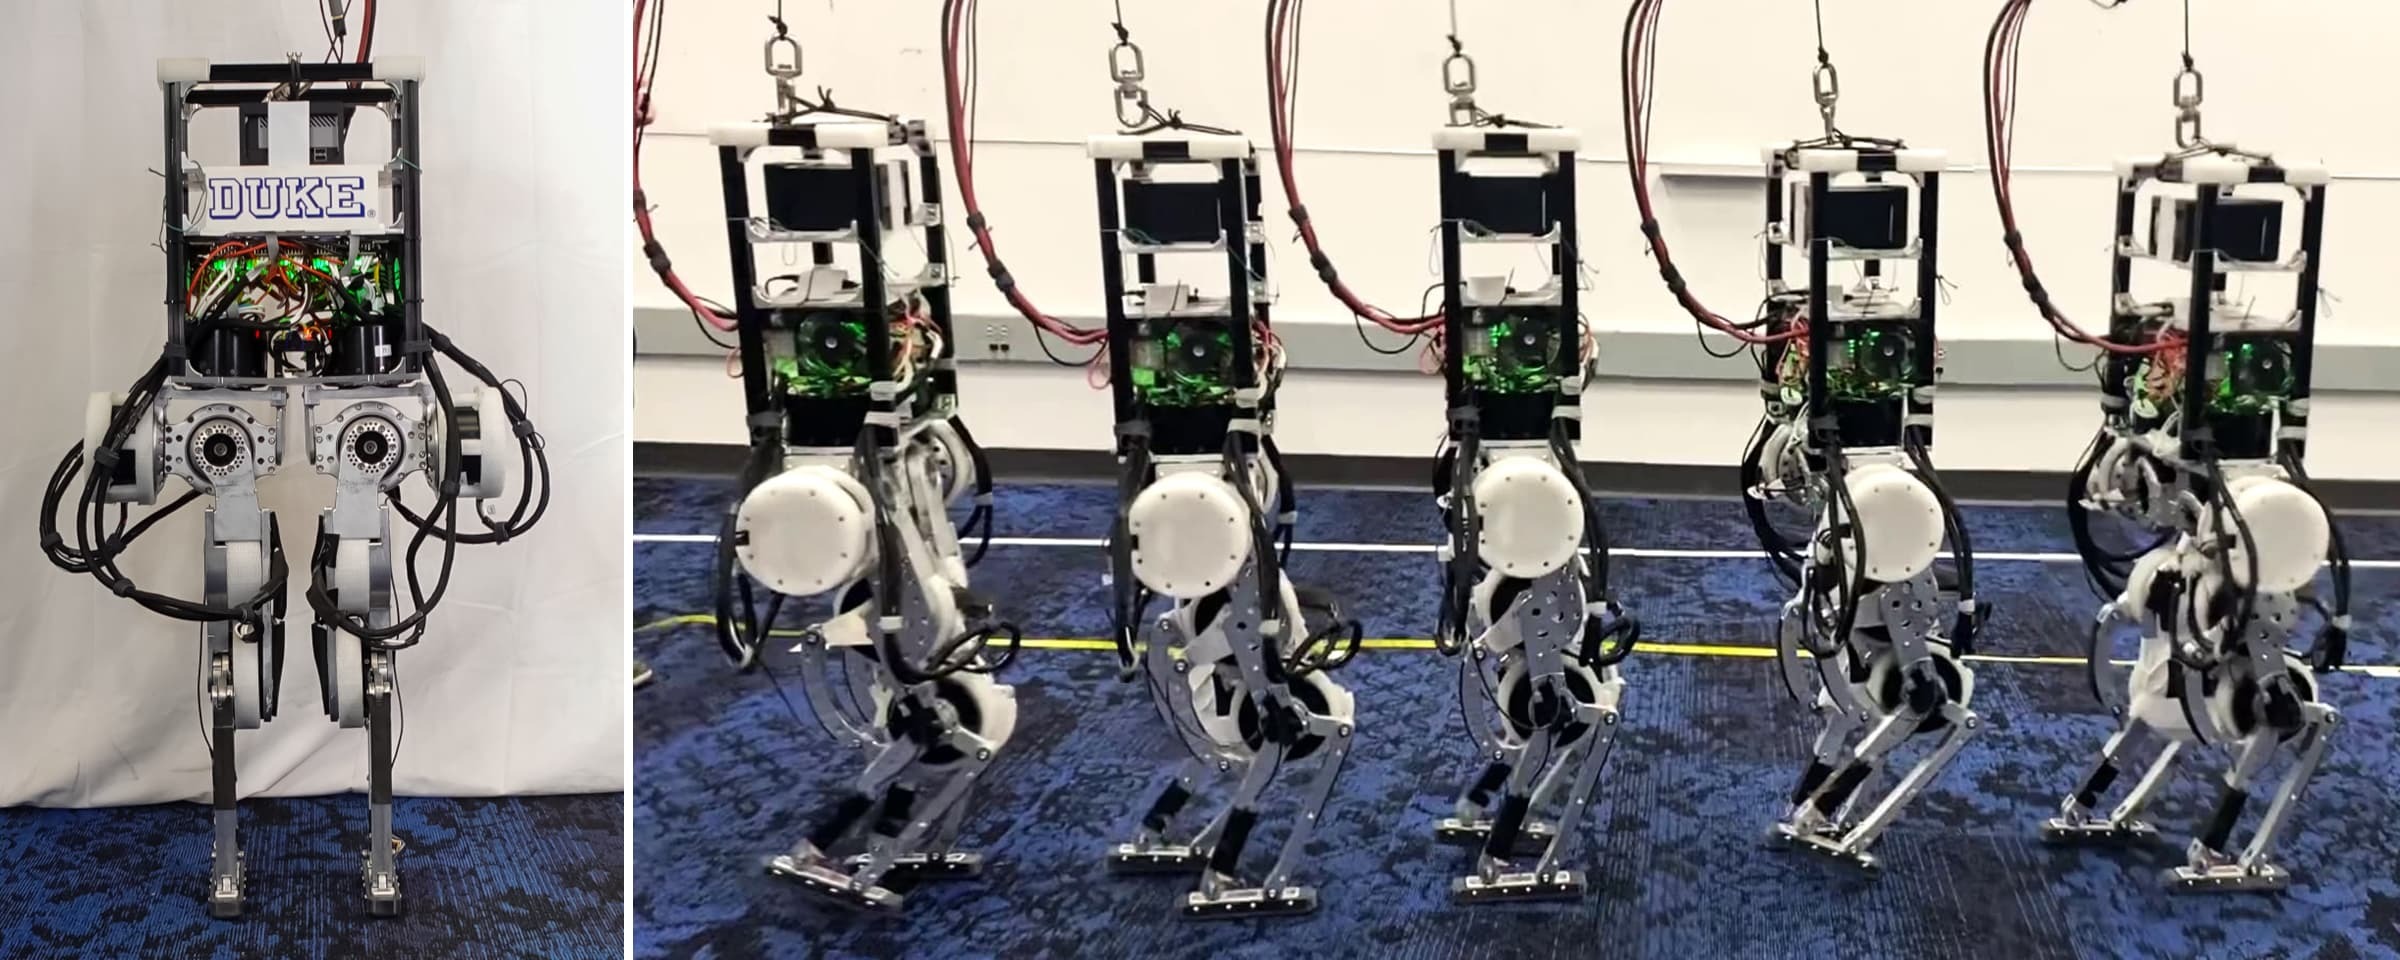
We designed a 10-DoF bipedal robot that mimics human physiology and a reinforcement learning policy that can leverage passive dynamics.
The Duke Humanoid taught us what it takes to build a humanoid. The goal here was to be human-like. This goal was not met. The truth is that designing aluminum to look like me and walk like me is ridiculous. Then why humanoids? Why this form? What functions can come out of this form?
Video
Authorship
Boxi Xia, Bokuan Li, Jacob Lee, Michael Scutari, and Boyuan Chen.